Tag Archives: mechanics

Forensic engineering

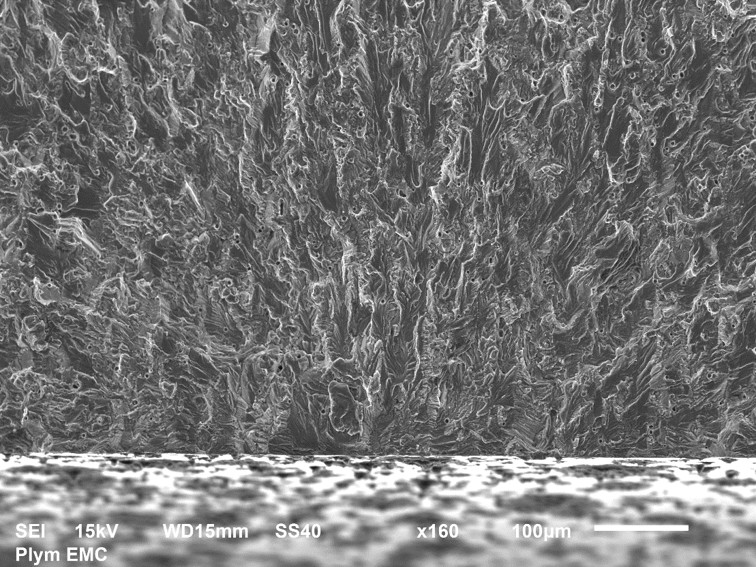
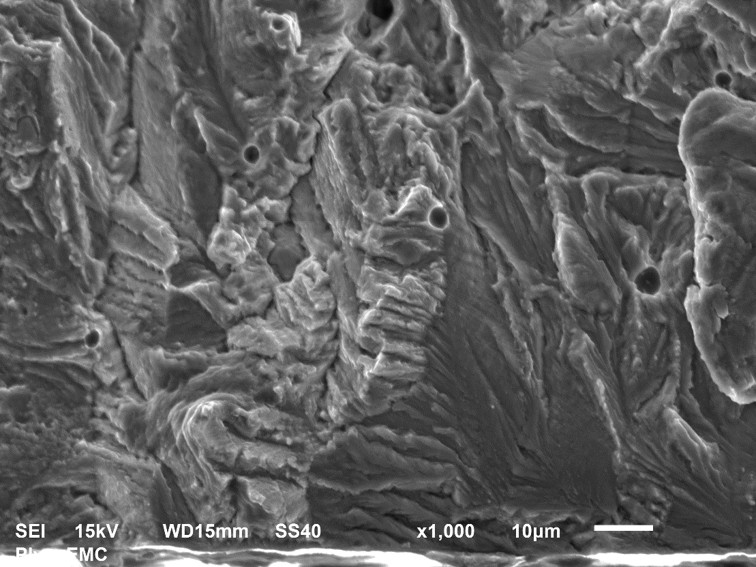
Picture1The picture above shows the fracture surface of a thin bar of aluminium alloy that had a circular hole through the middle, like the peep-hole in a front door. The photograph was taken in a Scanning Electron Microscope (SEM) at x160 magnification. There is a scale bar in the bottom right corner showing a length of 100 microns. We are looking approximately in the longitudinal direction, which was the direction of loading, and across the photograph from left to right corresponds to the direction you would look through the hole. The lower one third of the picture shows the machined surface of the hole cut or machined by the drill. The top two-thirds shows the surface created by the fatigue crack as it extended incrementally with each cycle of load. The crack started from edge of the machined surface approximately on the vertical centre-line of the picture. I can tell this because all of the features in the texture of the fracture surface point towards this point because the failure radiated out from this location. The picture below shows the crack initiation area at x1000 magnification. It is a small area at interface with hole above the letters ‘SS40’ in the top photograph; this should be enough to let you identify the common features but the interpretation of these images requires significant skill.

Fractography is the forensic study of failure surfaces such as this to establish the cause of failure. In this example, the hole in aluminium bar ensured that it will always fail with cyclic loading through the growth of a crack from somewhere around the hole. The textured form of the fracture surface occurs because the material is not homogeneous at this scale but made up of small grains. The failure of each grain is influenced by its orientation to the loading which results in the multi-faceted surface in the photographs.

I made the photographs the focus of this post because I thought they are interesting, but may be that’s because I’m an engineer, and because they are a tiny part in a fundamental research programme on which I have been spending a significant portion of my time. A goal of programme is to understand how to use these materials to build more energy-efficient structures that are cheaper and last longer without failing by, for example, fatigue.

More details:

The bar was 1.6mm thick and 38mm wide in the transverse direction and made from 2024-T3 Aluminium alloy. The hole diameter was 6.36mm. A tension load was repeatedly applied and removed in the longitudinal direction which caused the initiation and growth of a fatigue crack from the hole that after many cycles of loading led to the bar breaking in half along a plane perpendicular to the load direction. The pictures were taken at the University of Plymouth by Khurram Amjad with the assistance of Peter Bond and Roy Moate using a JEOL JSM-6610LV.
x1000

Robots with a delicate touch

whitesgroup demoCan a robot pick up an egg or a baby cactus without damaging either? If it is a conventional ‘hard’ robot then the answer is almost certainly ‘no’. But if it is a ‘soft’ robot then the answer is definitely ‘yes’. They can pick ripe tomatoes from the plant, too. And play the piano with a light touch.

These are all examples used by Professor George Whitesides to illustrate the capability of soft robots during a lecture that I attended last week. The occasion was a scientific discussion meeting on Bio-inspiration of New Technologies which was held to celebrate 350 years to publishing the Philosophical Transactions of the Royal Society. While I was in London listening live to Prof Whitesides and the other eight speakers, other people were listening via video links to Bangalore, India and Sao Paulo, Brazil.

Professor Whitesides’ ingenious robots have ‘fingers’ built from the same soft rubber that is used in implants. They are constructed with a solid layer on one face that is curled around the object being picked up by the inflation of compartments on the reverse face. The inflation of the compartments on the reverse face cause the face to lengthen and the ‘finger’ bends to accommodate the change in length. Careful design of the inflated compartments allows the fingers to conform to the shape being picked up and the use of microfluidics ensures it is not damaged.

Professor Whiteside identified star fish as the source of inspiration for the design of his soft robots. I don’t feel that this short piece has done justice to his work. If, nevertheless, you feel inspired to work for him then there’s probably a queue and since he is professor at Harvard it is almost certainly a long one. His research group has also spun out a company, Soft Robotics Inc. so you could buy some soft robots and explore their capabilities…

Cow bladders led to modern strain measurement


softball figureSir David Brewster was a prolific experimentalist who published seven papers in the Philosophical Transactions of the Royal Society during 1815 and 1816. In his report dated October 22nd, 1814 that was published by the Royal Society one hundred years ago in January 1815, he described his observations on the depolarisation in more than fifty materials as diverse as sulphur and the bladder of a cow. He followed this with a series of experiments on glass sheets subject to various loads and reported his observations in the of photographic plates that show photoelastic fringe patterns which would become instantly recognisable to generations of engineers. Two hundred year later, digital technology has revolutionised photoelasticity so that it is no longer necessary to generate fringes that can be ‘seen’, as in Brewster’s experiments. Instead, digital sensors allow us to measure changes in light intensity that are undetectable to the naked eye and digital computers permit the processing of arrays of tens of thousands of measurements in less than the blink of an eye to yield maps of strain magnitude and direction in complex components. However, the principles employed in digital photoelasticity are the same as those first elucidated by Brewster and involve collecting images at multiple rotational steps of one or more of the polarising elements in a polariscope and then using Fourier analysis or matrix algebra to solve the equations describing the stress-optic law, i.e. the relationship between the applied stress and the observed change in transmitted light intensity. A polariscope is the term given to the series of polarisers and quarter-waveplates used by almost every photoelastician since Brewster to observe photoelastic fringes. One of Brewster’s other great inventions was the kaleidoscope of which there is an early example in the Science Museum in London. Recently, the concept of the kaleidoscope has been combined with a polariscope to create the poleidoscope that allows the multiple images required for digital photoelasticity to be acquired simultaneously, which is useful for dynamic applications such as in the impact example shown in the picture. These advances allow digital photoelasticity to be used not only by laboratory-based stress analysts but also in quality assurance procedures, for instance to monitor in real-time the stresses induced in float glass during production, or to investigate the residual stress in silicon wafers using infra-red light.

The picture shows a sequence of maps of photoelastic fringe order (right) showing the stress induced in an epoxy resin block when impacted by a soft ball falling under gravity (left). The maps were obtained using a precursor to the poleidoscope and a high-speed digital camera recording 4000 frames per second for the 10x10mm area shown by the white box in the schematic.

For more a little more on photoelasticity see http://www.experimentalstress.com/basic_experimental_mechanics/photoelasticity.htm

Sources:

Brewster, D., Experiments on the depolarisation of light as exhibited by various mineral, animal , and vegetable bodies, with a reference of the phenomena to the general principles of polarisation, Phil. Trans. R. Soc. Lond. 105:29-53, 1815. http://rstl.royalsocietypublishing.org/content/105/29.full.pdf+html

Brewster, D., On the communication of the structure of doubly refracting crystals to glass, muriate of soda, fluor spar, and other substances by mechanical compression and dilatation, Phil. Trans. R. Soc. Lond. 106:156-178, 1816. http://rstl.royalsocietypublishing.org/content/106/156.full.pdf+html

Ramesh, K., Kasimayan, T., Neethi Simon, B., Digital photoelasticity – a comprehensive review, J. Strain Analysis, 46(4):245-266, 2011. http://sdj.sagepub.com/content/46/4/245.abstract

www.sciencemuseum.org.uk/online_science/explore_our_collections/objects/index/smxg-3823?agent=smxg-52657

Lesniak, J.R., Zhang, S.J., Patterson, E.A., The design and evaluation of the poleidoscope: a novel digital polariscope, Experimental Mechanics, 44(2):128-135, 2004.

Hobbs, J.W., Greene, R.J., Patterson, E.A., 2003, A novel instrument for transient photoelasticity, Experimental Mechanics, 43(4):403-409, 2003.

Thermodynamic Whoopee

man without a countryThe success of our students in the MyCopter project inspired me a couple of weeks ago to write about the prospect for flying cars [see post on October 2nd, 2014 entitled ‘Origami car-planes‘], which are not good essentially because we don’t know how to manipulate gravity. Everything in the universe is controlled by four forces, i.e. electromagnetic, gravitational, weak nuclear and strong nuclear. Adam Frank, described our understanding and control of electromagnetic forces as god-like because we can manipulate photons, electrons and atoms with enormous precision in flat screen TVs, mobile phones, microwave ovens and much more.

Strong nuclear forces hold protons and neutrons together in the nucleus of atoms and weak nuclear forces control the fusion process in stars. We have managed to take a few tottering steps to control nuclear forces in nuclear power stations but we are blundering apprentices compared to our skills with electromagnetism. However, with gravitational forces we are like toddlers trying to feed ourselves – we have some idea about what we are supposed to be doing but we waste an enormous amount in trying to hit the target. So we use our expertise in electromagnetism to combust fuel in an engine which drives an aerofoil through air faster enough to generate lift. This usually involves burning vast amount of fossil fuel and it gets worse when you want to hover with rotating blades or a vertical jet. Kurt Vonnegut in a ‘A Man without a Country‘ has described our reckless use of fossil fuel as making ‘thermodynamic whoopee’ but if we want fly long distances with significant payloads we don’t have much choice at the moment.

If physicists could work out how to manipulate gravitational forces it would not take engineers long to design and build flying cars that would be as advanced relative to today’s private jet as your tablet computer is relative to an abaqus.

Source:

‘I was promised flying cars‘ by Adam Frank in the New York Times on June 6th, 2014